
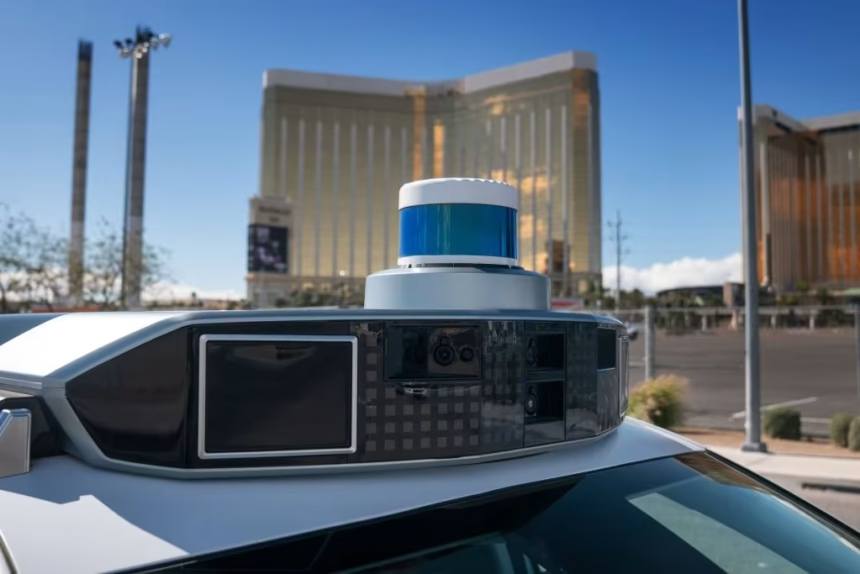
Researchers from MIT and autonomous vehicle company Motional have developed a new system called the Concept-Wrapper Network (CW-Net) that translates the opaque internal reasoning of an autonomous vehicle’s AI into understandable human concepts . The system explains decisions in real-time using concepts like ‘approaching stopped vehicle’ or ‘close to cyclist,’ making the decision-making process traceable for drivers and engineers . The research was published in the journal Nature .
Machine-learning-based planners act as the ‘brain’ of a self-driving car, processing data from cameras and lidar sensors to decide the next trajectory . These planners are typically black-box models, meaning their internal reasoning is so complex that it is difficult to understand why a vehicle makes unexpected decisions, such as phantom braking . CW-Net addresses this by embedding a concept classifier module into the existing planner architecture .
CW-Net translates the model’s internal reasoning into understandable concepts and then forces the final decision-making stage of the planner to use those concepts . This ensures the explanations are causally faithful, meaning they accurately reflect the true reasons behind the vehicle’s behavior, rather than being post-hoc justifications . The system outputs these clear explanations alongside the vehicle trajectory in real-time .
In private track tests, CW-Net explanations helped safety drivers more accurately predict vehicle behavior . A larger simulation study with non-expert users yielded similar results . In one test, a vehicle systematically stopped near a cyclist, and the safety driver assumed the car had correctly recognized the cyclist . CW-Net revealed the model was not properly configured to detect the cyclist and had chosen a trajectory that would have caused a collision, and the car was stopping due to emergency braking .
This insight corrected the driver’s understanding and allowed engineers to identify and fix the model’s underlying issue . In another test, CW-Net revealed a model was ‘hallucinating’ a stationary vehicle due to training data issues, and another time it showed that braking was triggered by a safety backup system rather than the deep-learning planner . These findings demonstrate how the system can help engineers troubleshoot AI systems and improve safety .
The researchers trained CW-Net on a dataset of 130 million examples of scenes from self-driving cars, with multiple labeled concepts in each scene . The system was deployed on public roads in Las Vegas as part of the research . Julie Shah, an MIT professor and co-senior author of the paper, said the work shows how explanations can support a human’s understanding of a system and be used to improve the technology . She added, ‘Unless we are building these technologies in a way that we can rely on and predict their behavior, then it is a shaky and unsafe foundation for their use’ .